Surface Robotic Systems
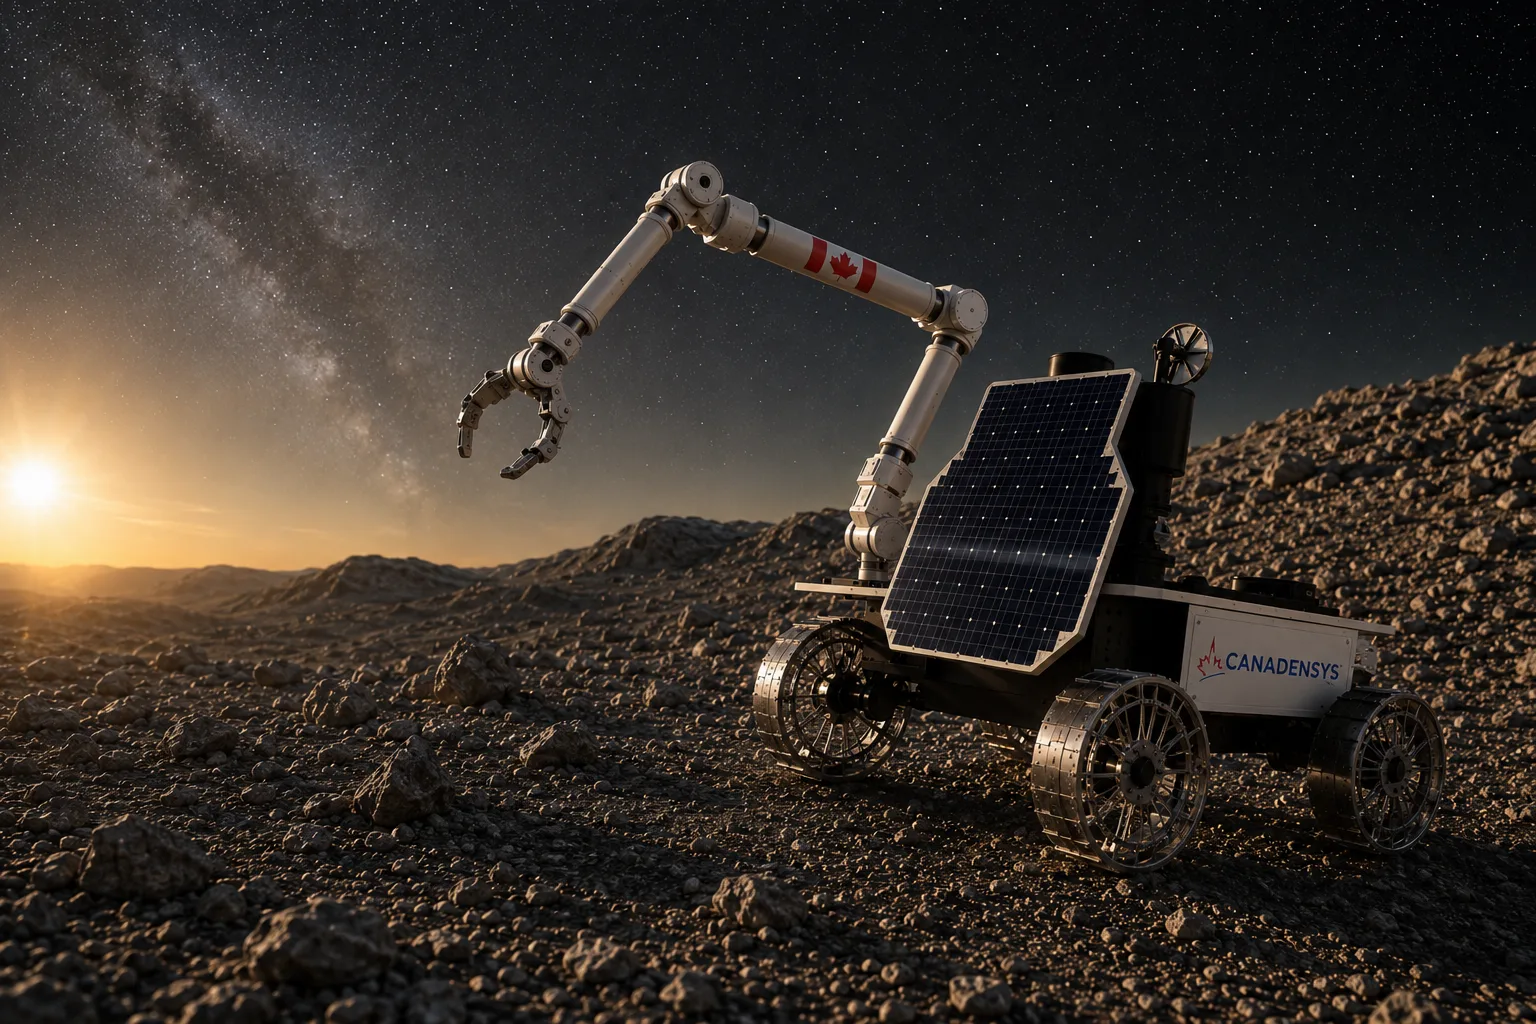
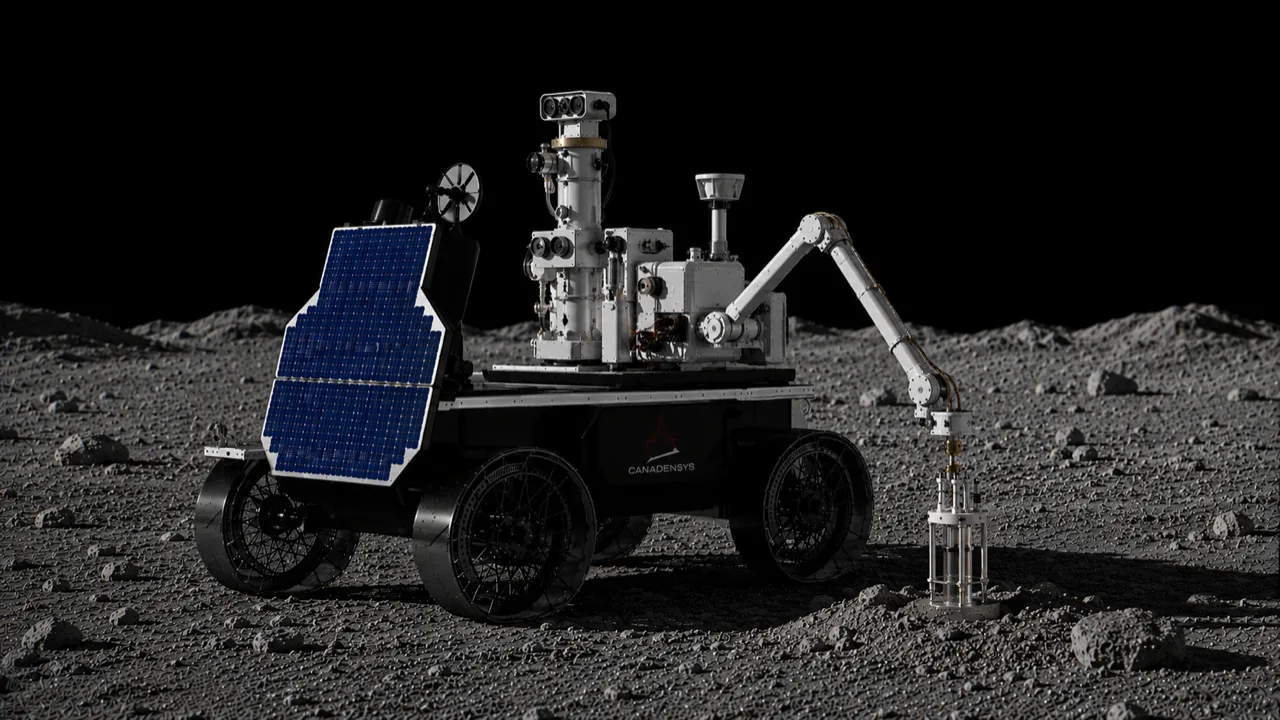
Robotics for working on the lunar surface.
Robotic Systems
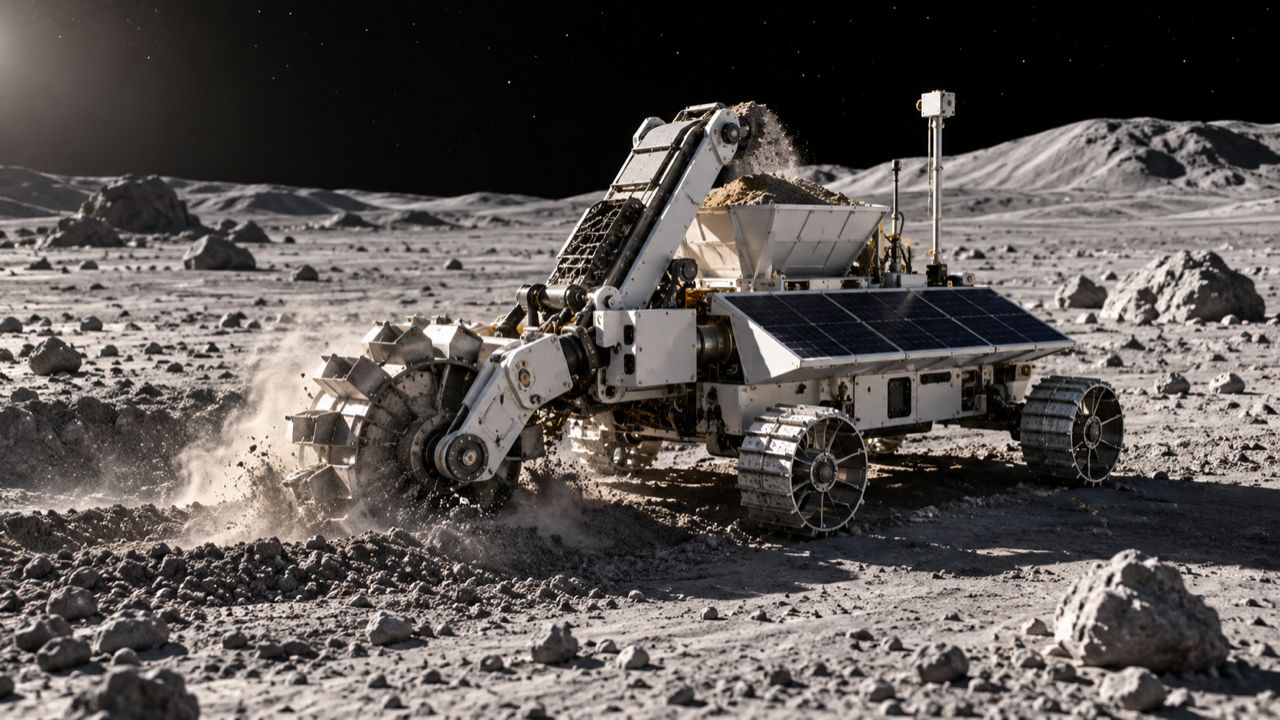
Resource mining
Excavation, analysis and regolith-processing systems for mining & ISRU applications.

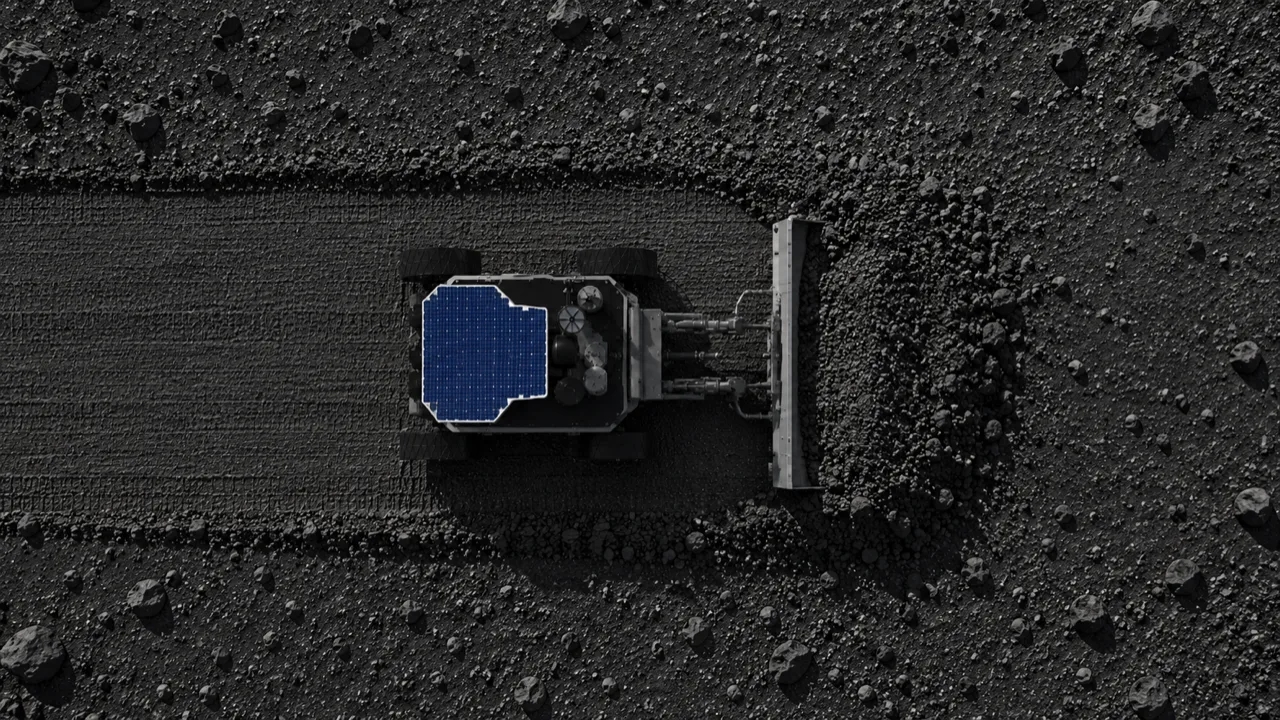
Utility dozer
Site-preparation blades and implements for lunar construction.

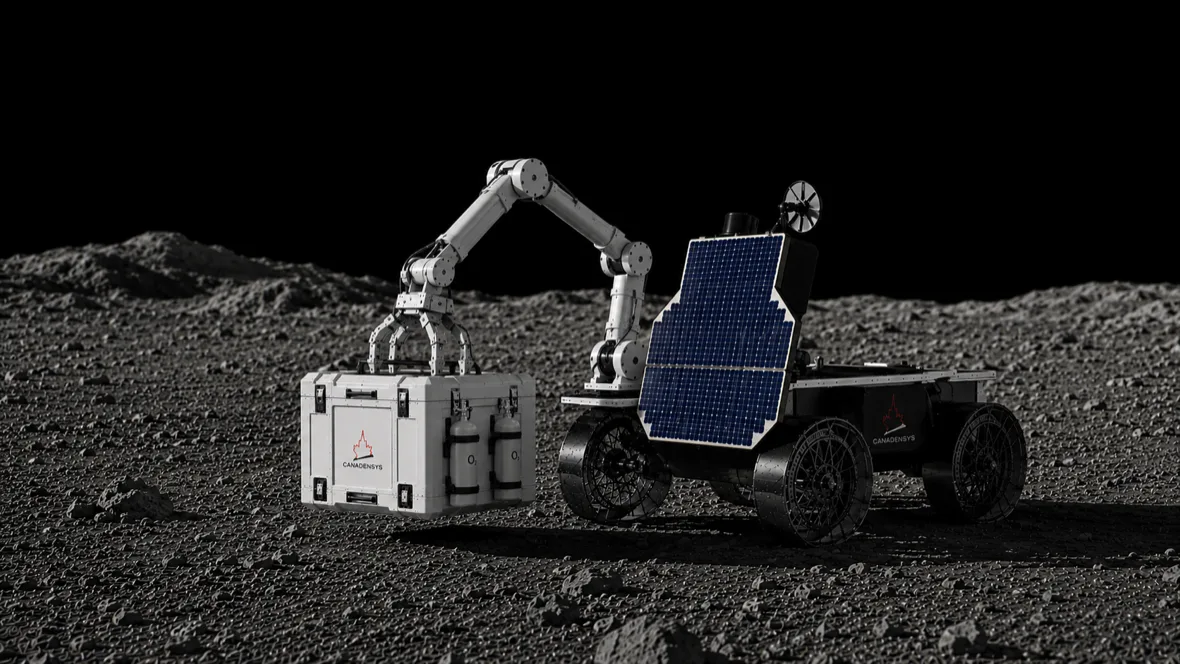
Manipulators
Arms and end-effectors for sample handling, servicing, and instrument deployment.
Core Capabilities
Guidance, navigation & control (GNC)
RF communications
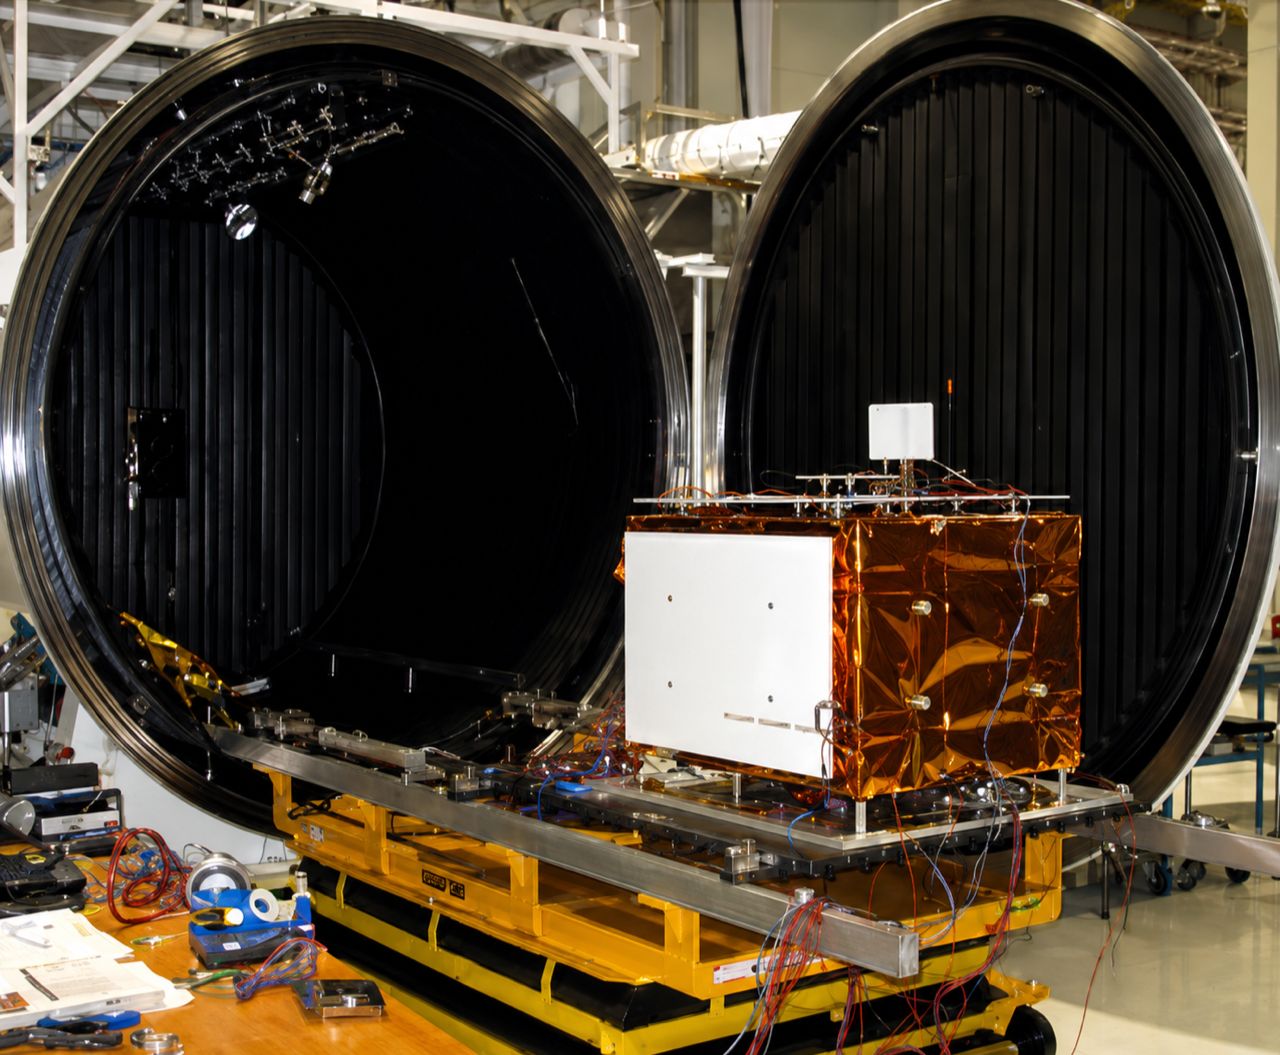
Lunar night survival
Permanently shadowed region (PSR) operations
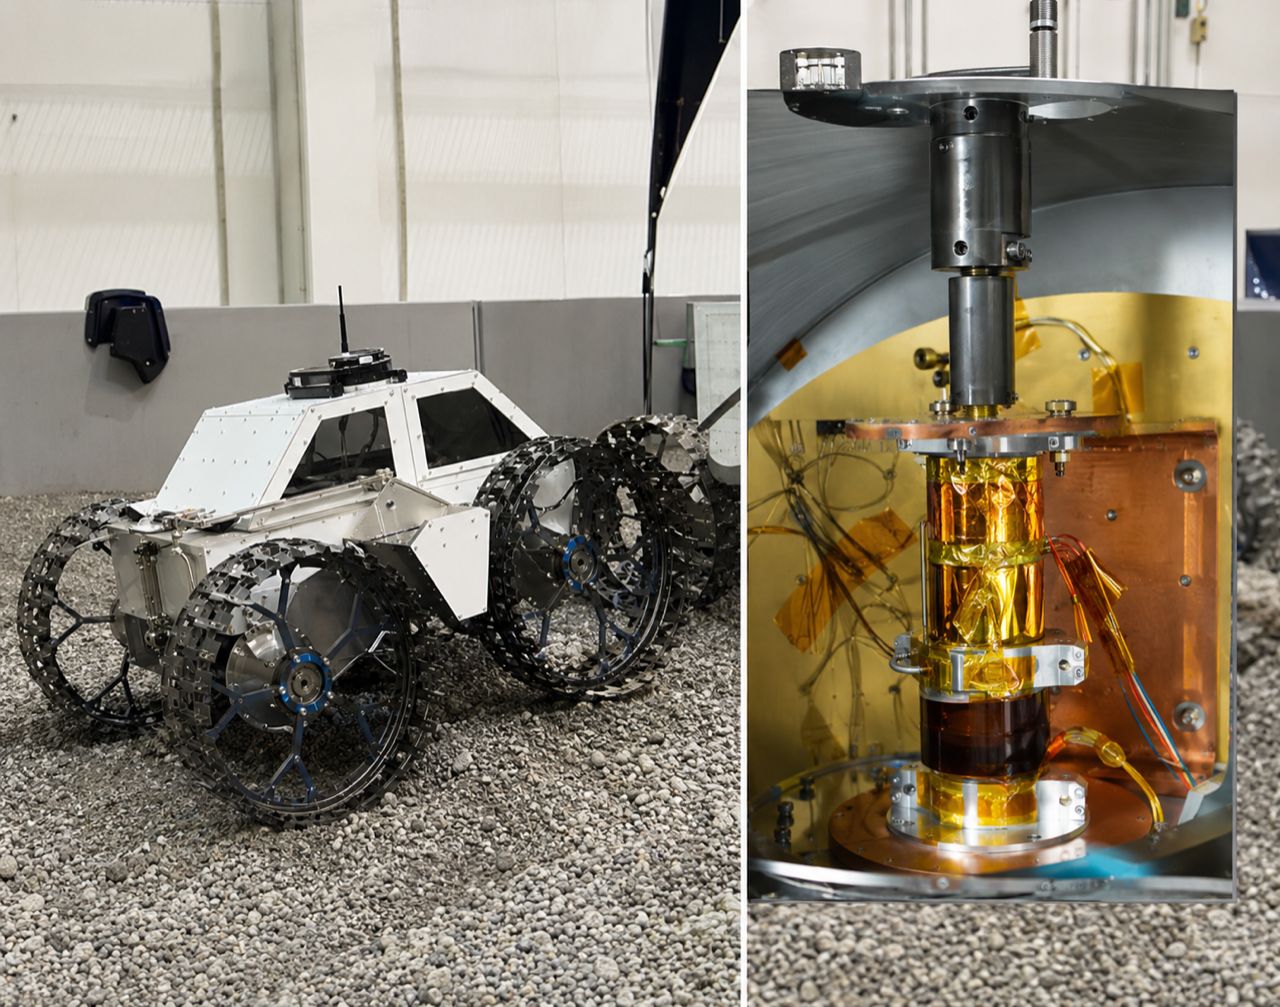
Have a surface robotics requirement?
Talk to the team that makes this hardware.